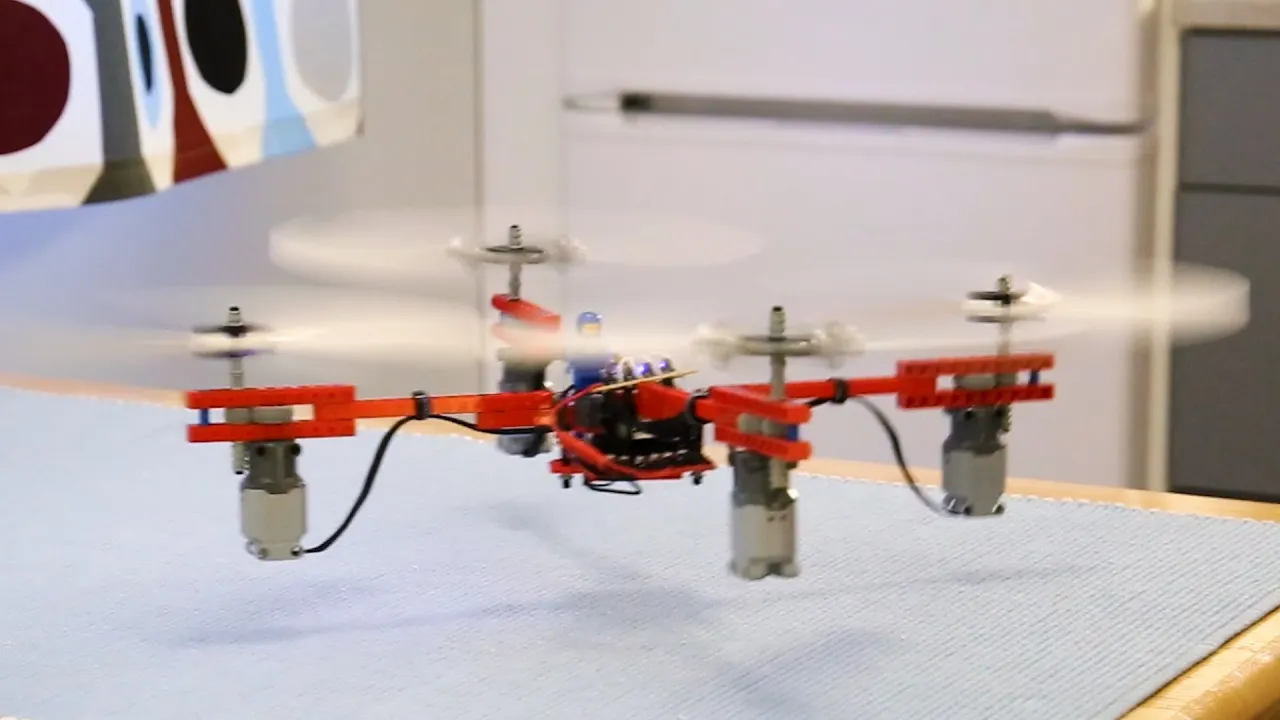
Making a Drone with Lego Motors and Propellers
 Brick Experiment Channel
Jan 11, 2020 15:29
Create an account to hide videos, mark them watched, or save them to Don't Miss.
Create an account to hide videos, mark them watched, or save them to Don't Miss.
Create an account to hide videos, mark them watched, or save them to Don't Miss.
The motors, propellers and frame are made of Lego. Non-Lego parts are the battery, radio receiver and flight controller. After building I fly this quadcopter indoors and outdoors. Enjoy!
Drone specs:
Motors (4x): Lego L-motor [88003-1]
Propeller blades (8x): Lego Propeller 1 Blade 14L [89509]
Gearing: 1:1.67 gear-up for each rotor
Frame: Lego liftarms and other Lego parts (look at component list)
Flight controller: Matek F411-mini
Motor driver circuit (4x): MOSFET IRLR2905 + Schottky diode 1N5819 + Resistor 12 kOhm (look at circuit diagram)
Radio receiver: FrSky R-XSR Micro 2.4GHz
Radio transmitter: FrSky X-Lite 2.4GHz
Battery: LiPo 9s 33.3V 200 mAh (made out of nine Turnigy nano-tech 200mAh 3.7V 35-70C Pico)
Weight with battery: 410 grams
Max thrust: 470 grams
Flight time: about 2 minutes
Betaflight settings diff:
---------------------------------------------------
# version
# Betaflight / STM32F411 (S411) 4.1.1 Nov 15 2019 / 12:55:17 (1e5e3d369) MSP API: 1.42
# manufacturer_id: MTKS board_name: MATEKF411 custom defaults: YES
# start the command batch
batch start
board_name MATEKF411
manufacturer_id MTKS
# resources
# Note: pass telemetry to transmitter (http://www.mateksys.com/?portfolio=f411-mini#tab-id-4)
resource MOTOR 5 NONE
resource SERIAL_TX 11 B03
# feature
feature -AIRMODE
# map
map TAER1234
# serial
serial 30 32 115200 57600 0 115200
# aux
aux 0 0 0 1700 2100 0 0
aux 1 1 1 900 1700 0 0
aux 2 28 1 1300 2100 0 0
aux 3 47 1 1700 2100 0 0
# master
set min_throttle = 700
set min_command = 0
set use_unsynced_pwm = OFF
set motor_pwm_protocol = OFF
set motor_pwm_rate = 480
set align_board_yaw = 135
set pid_process_denom = 16
set gyro_1_align_yaw = 1800
profile 0
# profile 0
set p_pitch = 200
set i_pitch = 0
set d_pitch = 0
set f_pitch = 0
set p_roll = 200
set i_roll = 0
set d_roll = 0
set f_roll = 0
set p_yaw = 60
set d_min_roll = 0
set d_min_pitch = 0
rateprofile 0
# rateprofile 0
set roll_rc_rate = 50
set pitch_rc_rate = 50
# end the command batch
batch end
Science & Technology
#Lego Technic
#quadcopter
#drone
#thrust test
#electronics
#veroboard
#dc motor
#brushed motor
#pwm
#pid tuning
#lego spaceman